Robot Path Planner
BFS, Dijkstra, A*, Greedy, RRT and RRT* - the same map, a robot with real size.
What is this?
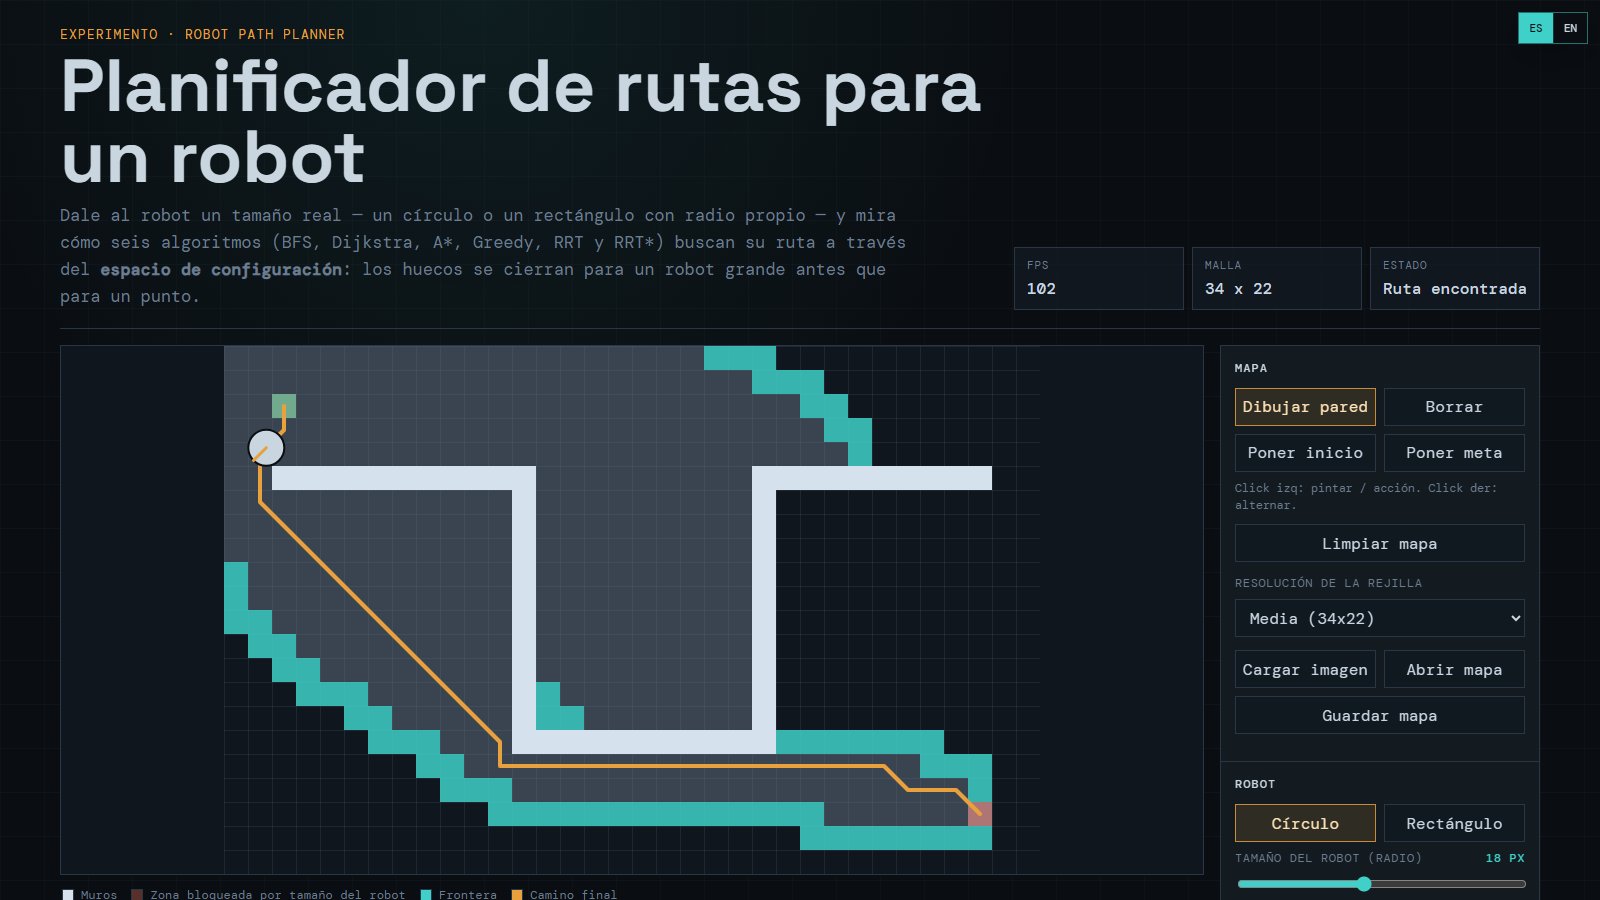
An interactive path-planning lab where the robot is not a dot: it has a real circular or rectangular footprint, so obstacles get inflated into a configuration space before any algorithm searches it. A narrow gap a single point could cross may close completely once the robot is large enough.
How it works
Draw walls (or import an image as a map), place start and goal, then run BFS, Dijkstra, A*, Greedy Best-First, RRT or RRT*. Grid algorithms show their visited cells and frontier; RRT and RRT* grow a random tree in continuous space. A comparison table runs all six on the same map so you can see who explores less and who actually finds the shortest path.